Portfolio
Projects
Each case study is a full build: problem, approach, hardware, debugging, and measured results — not just a demo reel.
2 / 2 shown
 Featured2026
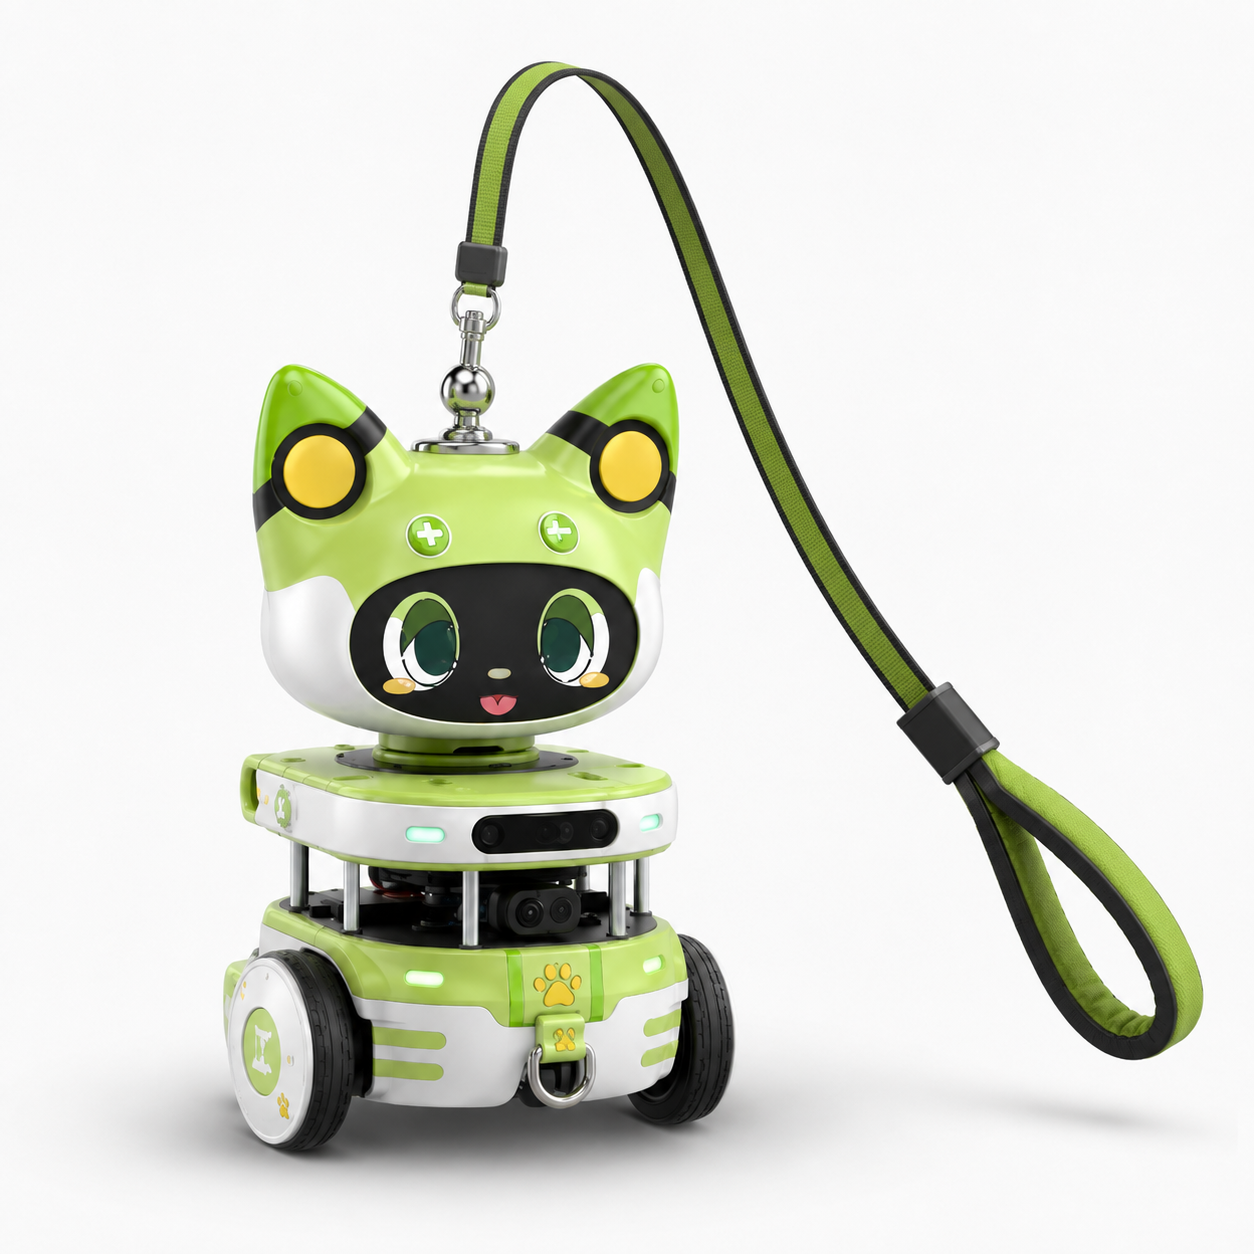
Scout — Robot Guide Dog
20 HzControl loopBuilt Scout, a TurtleBot3-based robot guide dog with real-time crosswalk and traffic-light vision, LiDAR person-tracking, and a fail-safe velocity-gate stack — led perception and safety-control on a 4-person Human-Robot Interaction team.
Fail-safe velocity gate stopped Nav2 output within one 20 Hz control tick of a latched red light, verified against a mock red/green signal rig with zero false passes.
ROS2Computer VisionTurtleBot3Human-Robot InteractionCase study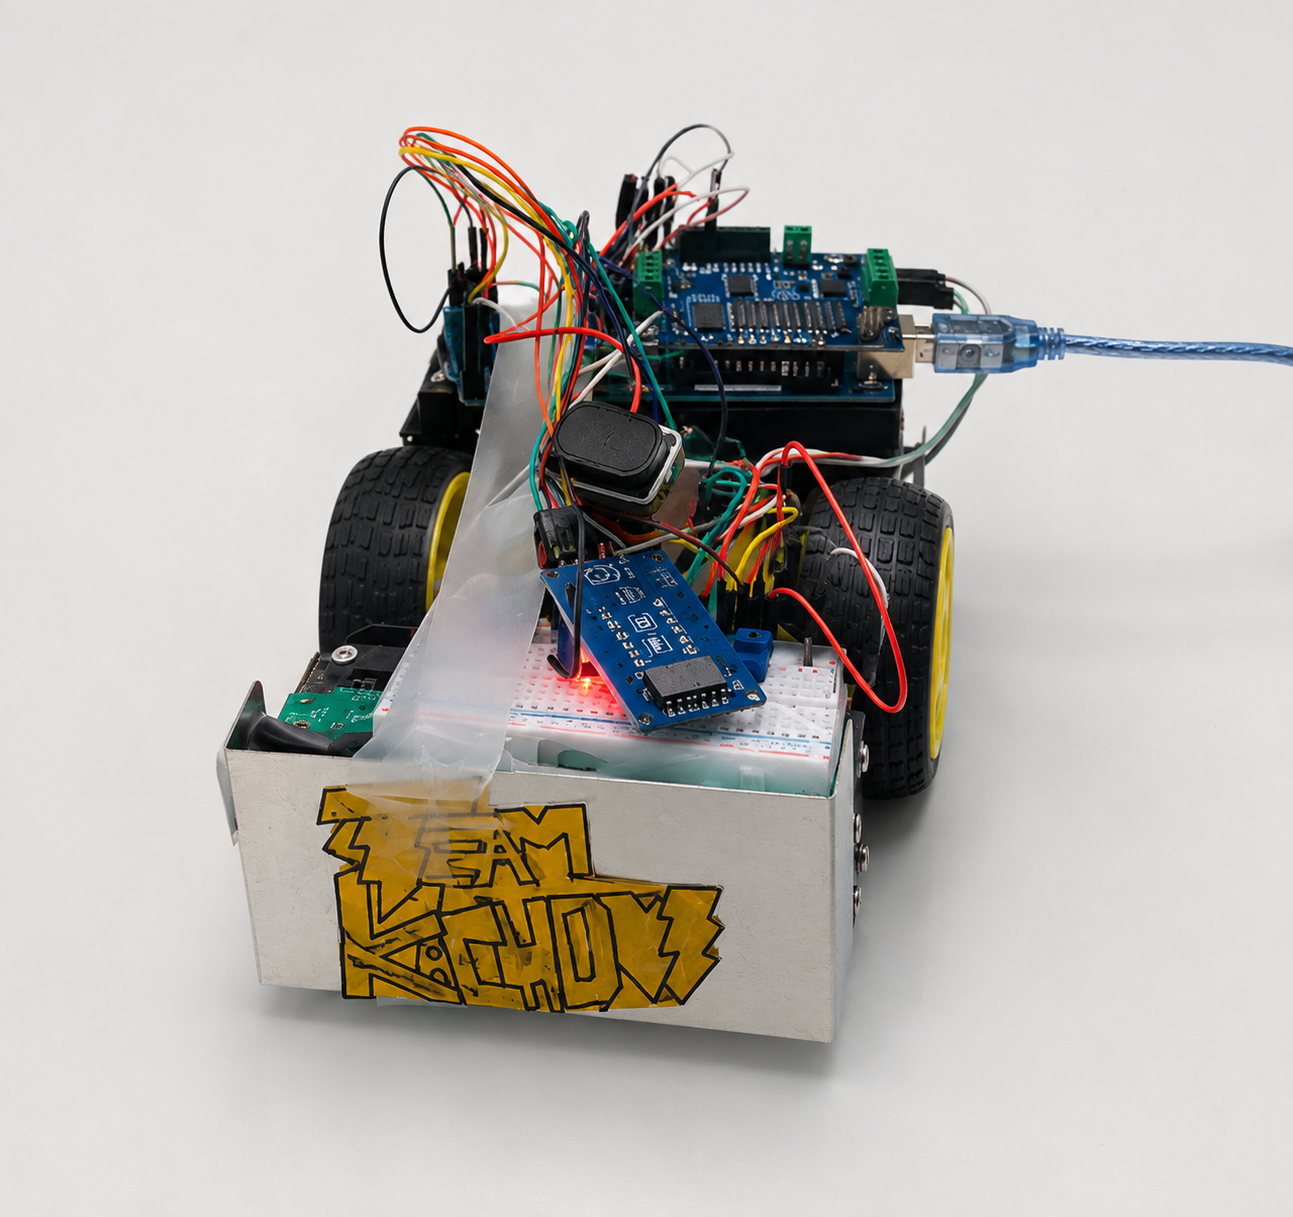 Featured2026
Line-Following Robot
7 photoresistorsSensorsPID-tuned line follower that completed the course using seven photoresistors, a custom PCB, a 3D-printed chassis, and a light shield — finished the entire track with one manual nudge due to surface bumps.
Completed the full track; required a single nudge mid‑course due to surface bumps.
Line FollowerArduinoPIDCustom PCBCase study